DEBATE2CREATE: Robot Co-design via Multi-Agent LLM Debate
Published: July 2026
Conference: Proceedings of the 43rd International Conference on Machine Learning (ICML 2026), Seoul, South Korea. PMLR 306, 2026.
Authors: Kevin Qiu, Marek Cygan
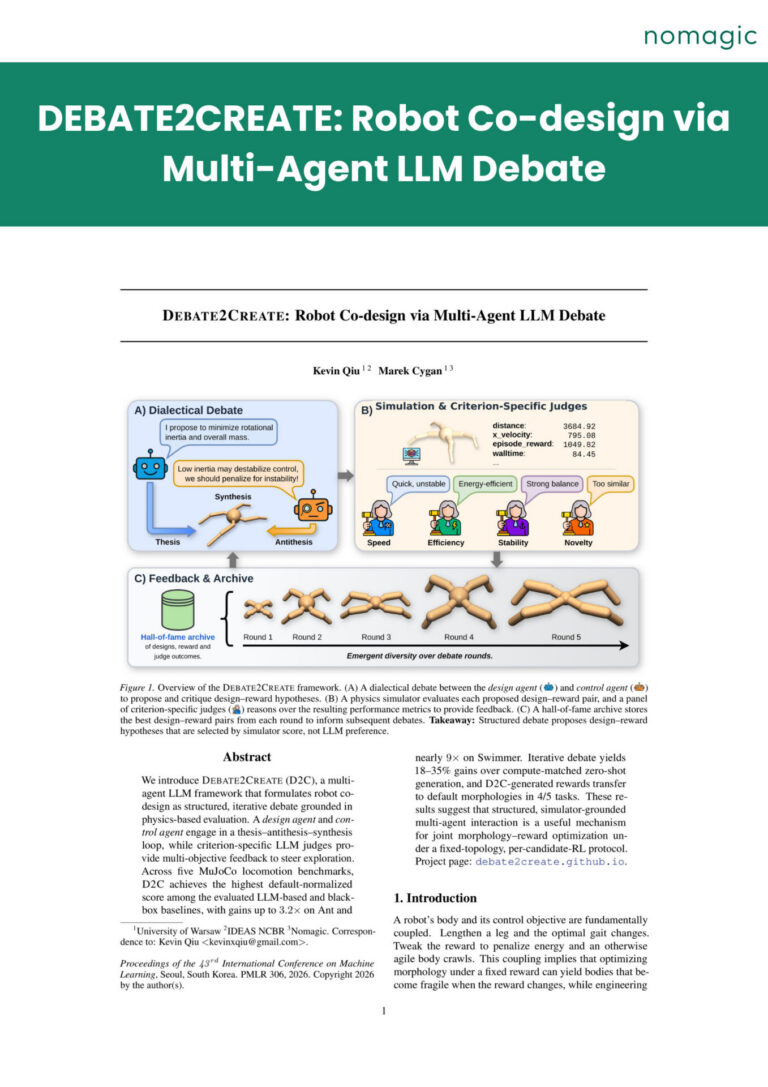
Abstract: We introduce DEBATE2CREATE (D2C), a multiagent LLM framework that formulates robot codesign as structured, iterative debate grounded in physics-based evaluation. A design agent and control agent engage in a thesis–antithesis–synthesis loop, while criterion-specific LLM judges provide multi-objective feedback to steer exploration. Across five MuJoCo locomotion benchmarks, D2C achieves the highest default-normalized score among the evaluated LLM-based and blackbox baselines, with gains up to 3.2× on Ant and nearly 9× on Swimmer. Iterative debate yields 18–35% gains over compute-matched zero-shot generation, and D2C-generated rewards transfer to default morphologies in 4/5 tasks. These results suggest that structured, simulator-grounded multi-agent interaction is a useful mechanism for joint morphology–reward optimization under a fixed-topology, per-candidate-RL protocol. Project page: debate2create.github.io.